Events
PAST EVENTS
A Foundation-First Perspective on Spatial AI: Geometry, Memory, and Agents
The seminar is open to Stanford faculty, students, and sponsors.
The Foundation Trilogy – Improving proficiency for generalizable autonomy
The seminar is open to Stanford faculty, students, and sponsors.
Contact: The Problem and the Path to Robotic Dexterity
The seminar is open to Stanford faculty, students, and sponsors.
Snakes, Search, and Space: Taming Many Degrees of Freedom
The seminar is open to Stanford faculty, students, and sponsors.
Adaptive Robotics Systems Using Embodied Intelligence
The seminar is open to Stanford faculty, students, and sponsors.
When Robots Feel Like Companions: Designing Trust and Agency with Older Adults
This seminar is open to Stanford faculty, students, staff, and sponsors.
Skydio: Autonomy for a Family of Flying Robots
The seminar is open to Stanford faculty, students, and sponsors.
Bridging rigorous methods with machine learning to build safe and intelligent autonomy
The seminar is open to Stanford faculty, students, and sponsors.
Evaluate, Detect, Adapt: Trustworthy Deployment of Large Behavior Models
The seminar is open to Stanford faculty, students, and sponsors.
Robotic Ultrasound for Healthcare Applications
This seminar is open to Stanford faculty, students, staff, and sponsors.
SRC Summer Presentations (#3)
This seminar is open to Stanford faculty, students, staff, and sponsors.
SRC Summer Presentations (#2)
This seminar is open to Stanford faculty, students, staff, and sponsors.
SRC Summer Presentations (#1)
This seminar is open to Stanford faculty, students, staff, and sponsors.
Robots with Character: Solving the interface problem for home robotics
This seminar is open to Stanford faculty, students, staff, and sponsors.
Autonomous Navigation on the Moon: Rovers, Drones and Humanoids
This seminar is open to Stanford faculty, students, staff, and sponsors.
Soft and Deployable Robotics for Extreme Environments
This seminar is open to Stanford faculty, students, staff, and sponsors.
From Laboratory to Clinic: Wearable Robots and Rehabilitation Outcomes
This seminar is open to Stanford faculty, students, staff, and sponsors.
Swap the Tool, Not the Robot: The Case for Multi-Purpose Industrial Platforms
This seminar is open to Stanford faculty, students, staff, and sponsors.
Forming / Moving / Making – Meaning
This seminar is open to Stanford faculty, students, staff, and sponsors.
Shaping the Future of Human-Robot Collaboration
This seminar is open to Stanford faculty, students, staff, and sponsors.
When Robots Care: Medical Robotics from Hospital to Home
This seminar is open to Stanford faculty, students, staff, and sponsors.
Dexterous Teleoperation: Challenges and Opportunities
The seminar is open to Stanford faculty, students, and sponsors.
Model Matters: Leveraging Geometry in Robot Learning
The seminar is open to Stanford faculty, students, and sponsors.
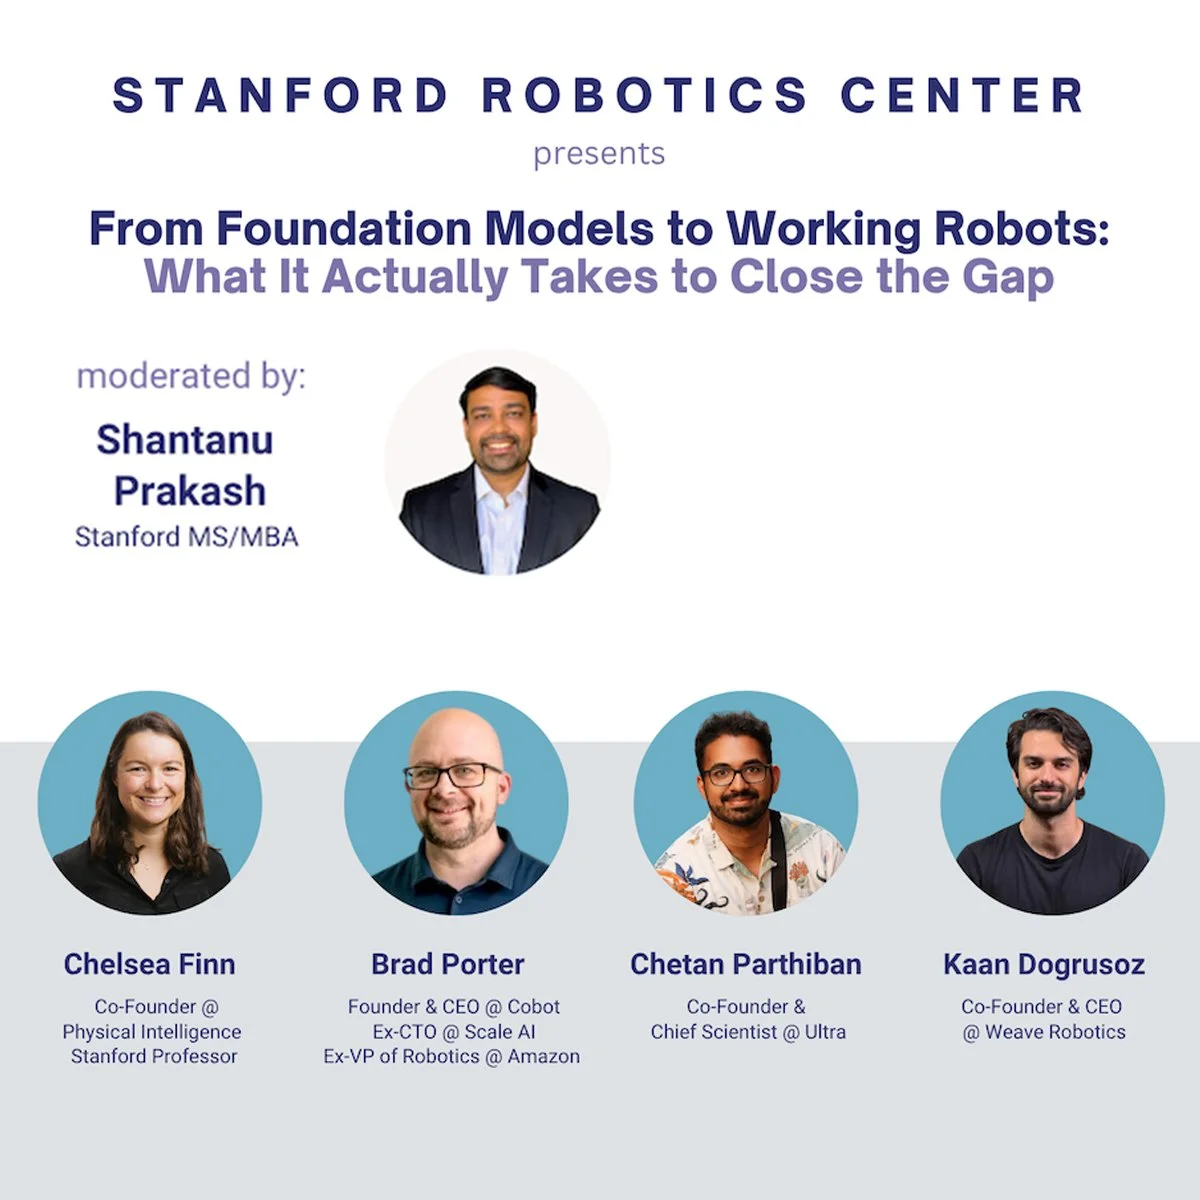
From Foundation Models to Working Robots: What It Actually Takes to Close the Gap
The seminar is open to Stanford faculty, students, and sponsors.
Towards Trustworthy Autonomy: Guardrails to detect, avoid, and learn from failures / Learning Dexerity from Humans
The seminar is open to Stanford faculty, students, and sponsors.
The Future of Intelligent Automated Logistics
The seminar is open to Stanford faculty and students.
Material Matters: Sensors and Actuators for Contact-Rich Robotics
The seminar is open to Stanford faculty, students, and sponsors.
Dane Brouwer PhD Defense: "Embodied, Reflexive, and Multimodal Intelligence for Manipulation in Unstructured Environments"
- Stanford University (map)
- Google Calendar ICS
In this talk, I will discuss 3 projects which enable robots to manage unstructured environments by using embodied, reflexive, and multimodal strategies.
The seminar is open to everyone.
Won Kyung Do PhD Defense: "Improving Robotic Dexterity with Optical Tactile Sensor DenseTact"
- Building 520, 131 (map)
- Google Calendar ICS
Dexterous manipulation - especially when objects are small, cluttered, or partially occluded - remains a complex challenge in robotics. In this talk, I present three approaches to tackling this problem using DenseTact, a family of soft, vision‑based tactile sensors.
The seminar is open to everyone.